Portrait of Burhanuddin Shirose

PhD Researcher, Robotics Institute, Carnegie Mellon University
AirLab · Advisor Prof. Sebastian Scherer

Burhanuddin ShiroseMotion planning for constrained and multi-agent robots.

I build planners that hold up on real hardware: coverage of unknown spaces, ergodic search in clutter, snake-robot reaching, and heterogeneous field teams.

M.S. Mechanical Engineering Carnegie Mellon University GPA 3.90 / 4.0
B.Tech Mechanical Engineering NIT Tiruchirappalli GPA 8.41 / 10
About

I am a PhD researcher at the Carnegie Mellon University Robotics Institute, working in the AirLab with Prof. Sebastian Scherer. As a Robotics Engineer at CMU (2023 to 2025) I built real-time planners for ground vehicles, decentralized multi-robot teams, and a multi-arm hardware-in-the-loop testbed. I hold an M.S. in Mechanical Engineering from CMU and a B.Tech in Mechanical Engineering from NIT Tiruchirappalli.

01Selected research

Figures and video from the papers and experiments
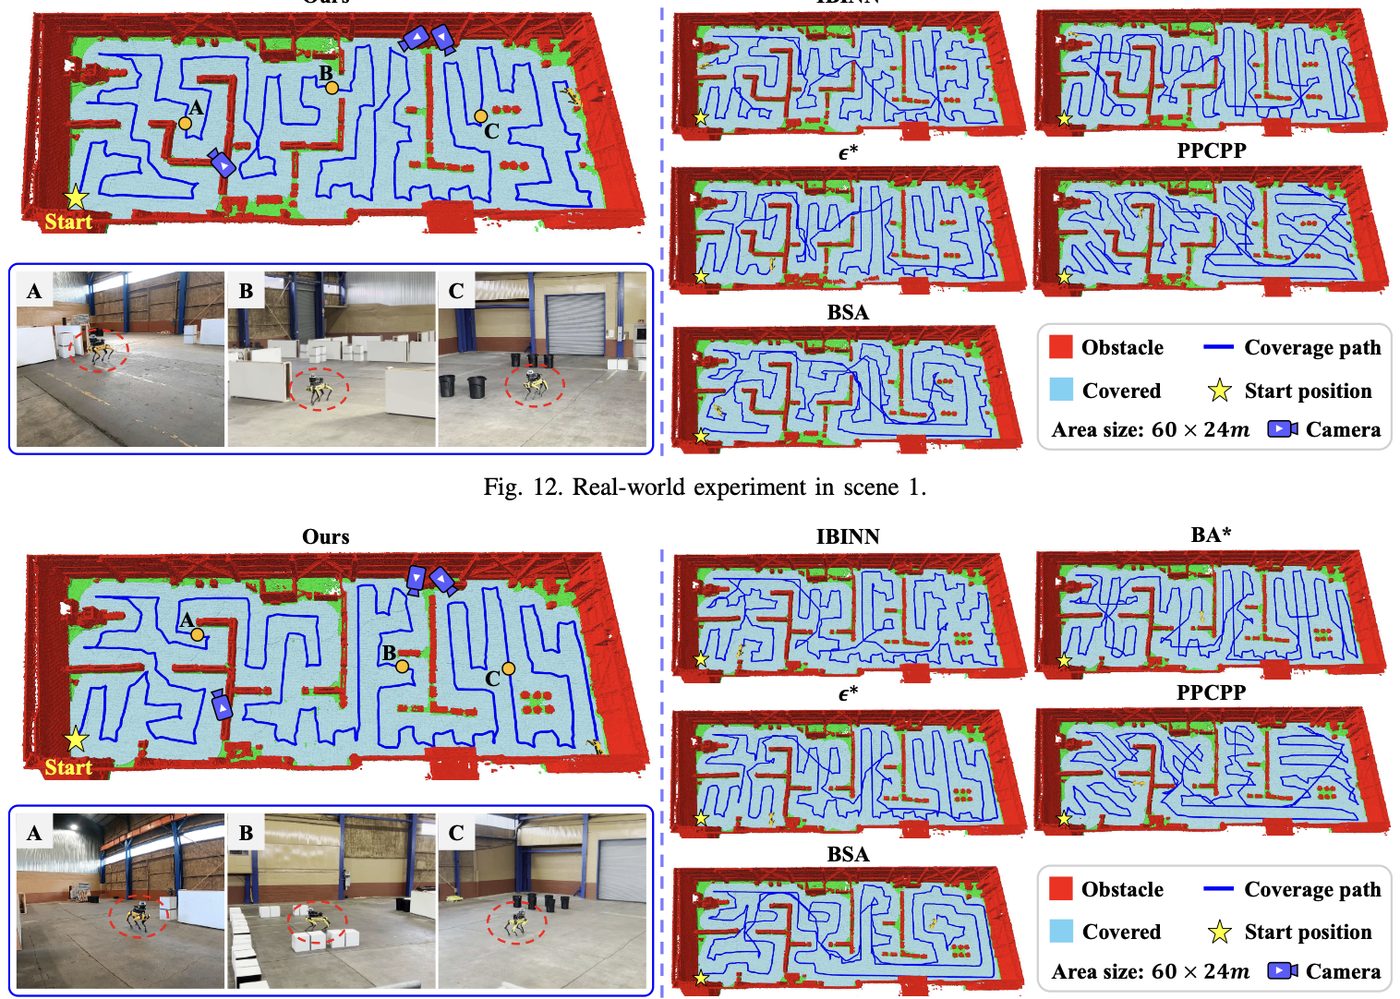
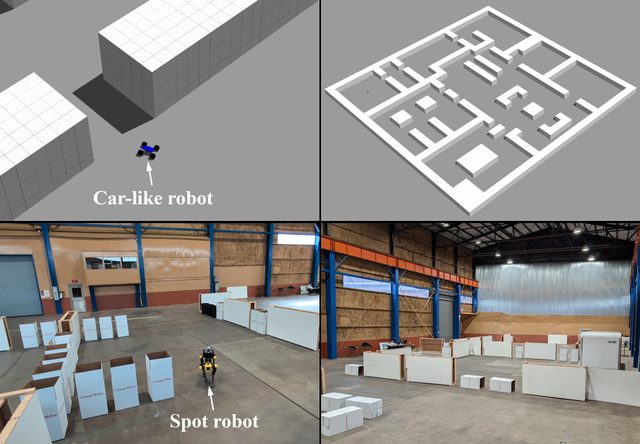
Warehouse experiment, 60 m × 24 m, 50× speed
IROS 2025IEEE Trans. (TAP)

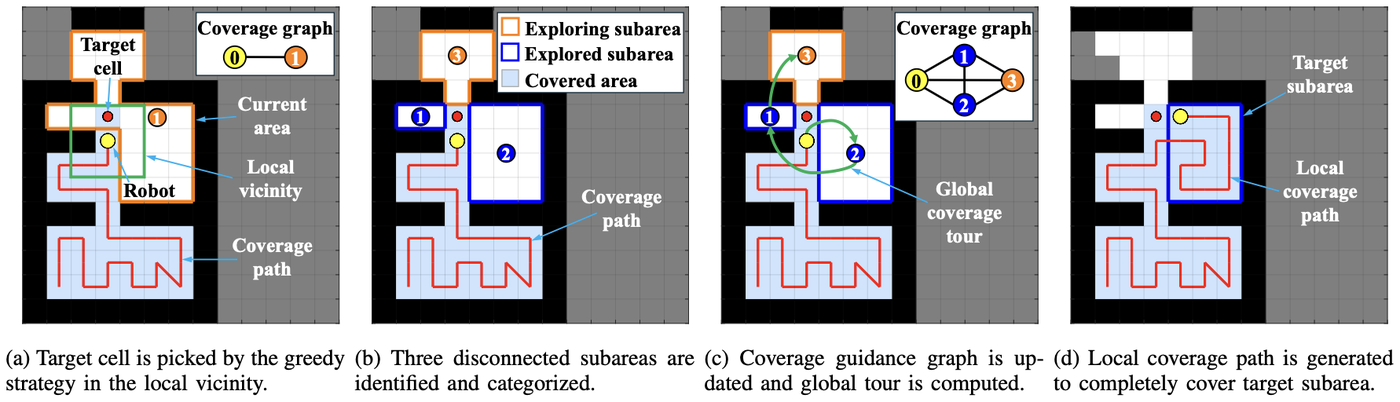
Connectivity-aware coverage path planning in unknown environments

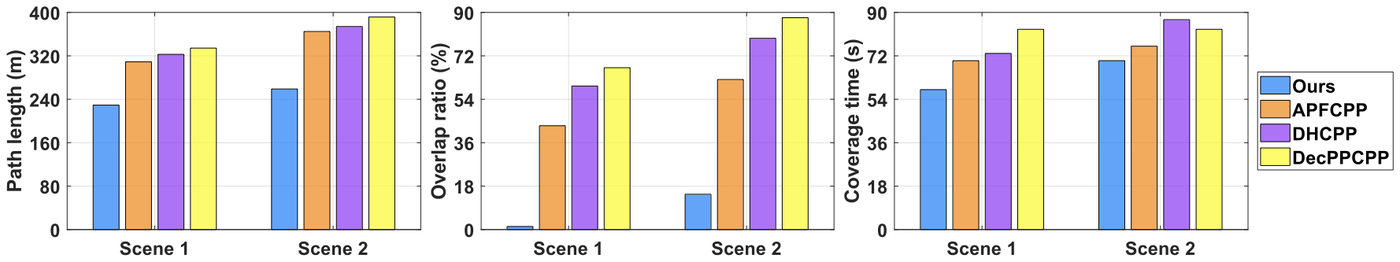
CAP builds a coverage guidance graph online from LiDAR that records how explored and unexplored subareas connect. A hierarchical planner orders subareas with a global tour and covers each one locally, which removes the revisits that greedy frontier planners make. Tested in simulation and on Spot and wheeled robots in 60 m × 24 m warehouses.

−20%total coverage time
−15%traversal in unknown space
5baselines compared
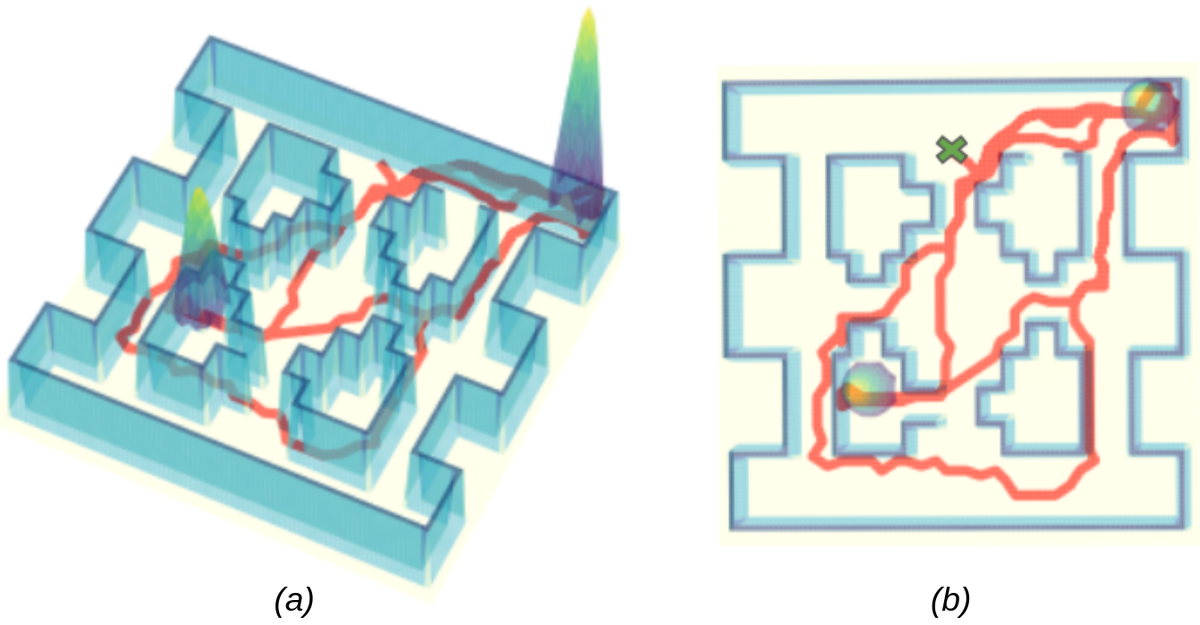
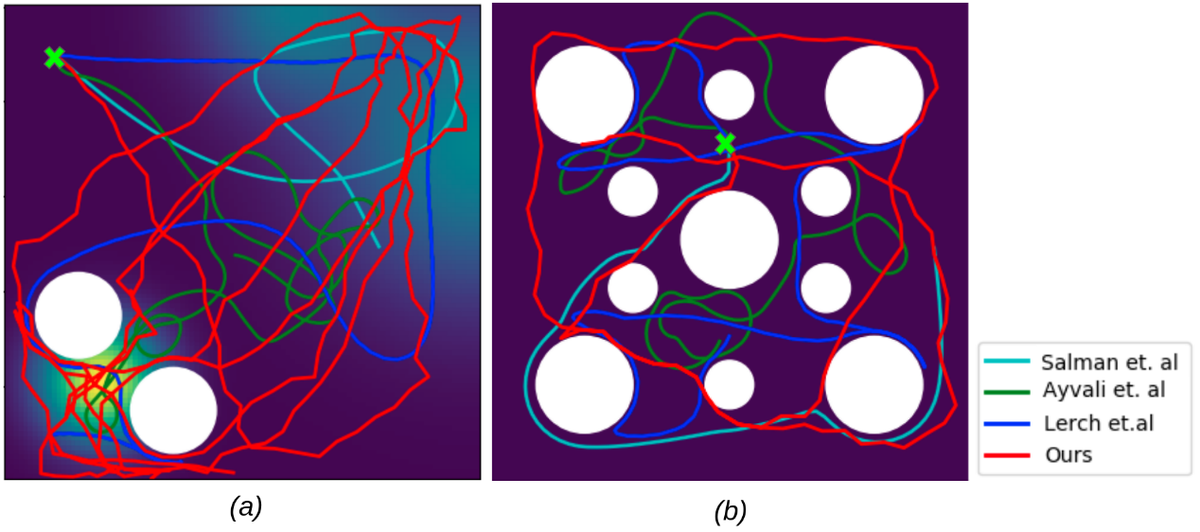
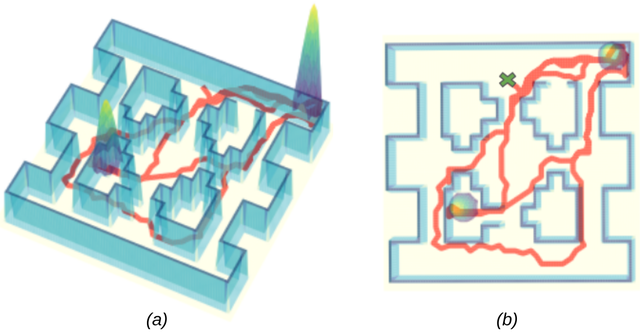
GESCE Figure 1: 3D maze with an information peak and the planned ergodic trajectoryErgodic path through a cluttered maze
IROS 2024First author

Graph-based ergodic search in cluttered environments

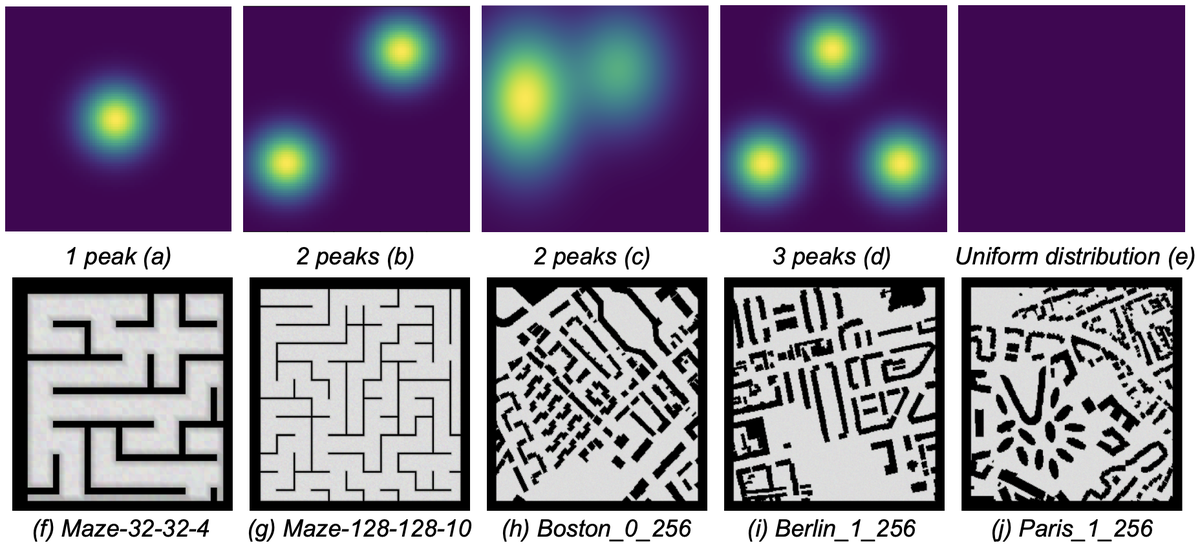
Ergodic planners spend time where targets are likely, but treat obstacles as soft costs and can still collide. GESCE builds a graph of the free space and searches it with ergodicity as the heuristic, so paths are collision-free by construction.

125benchmark scenarios
100%collision-free paths
5MAPF clutter maps
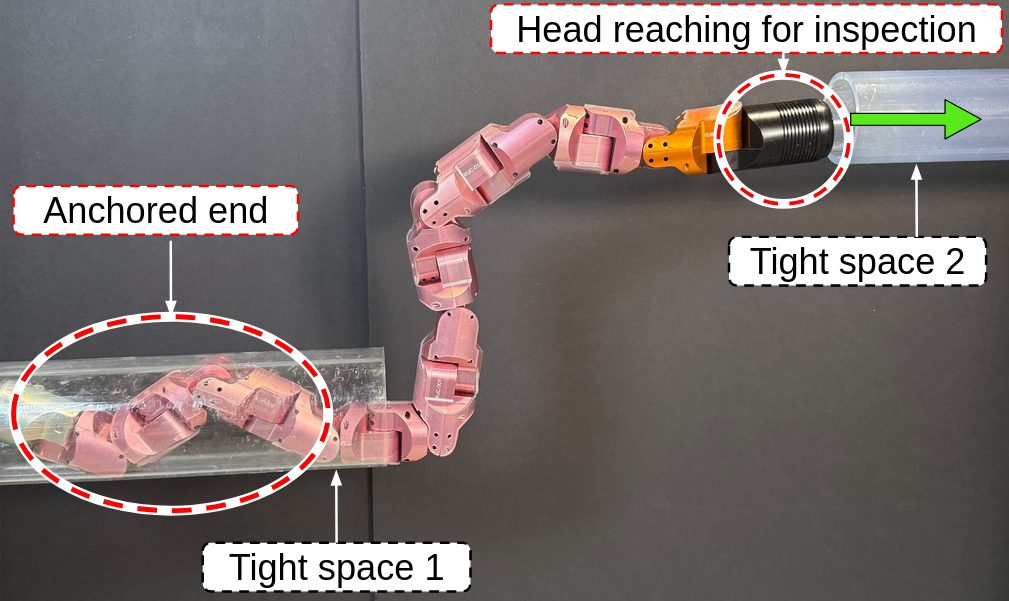
Reaching between tight spaces, 3× speed
IEEE RA-LIn preparation

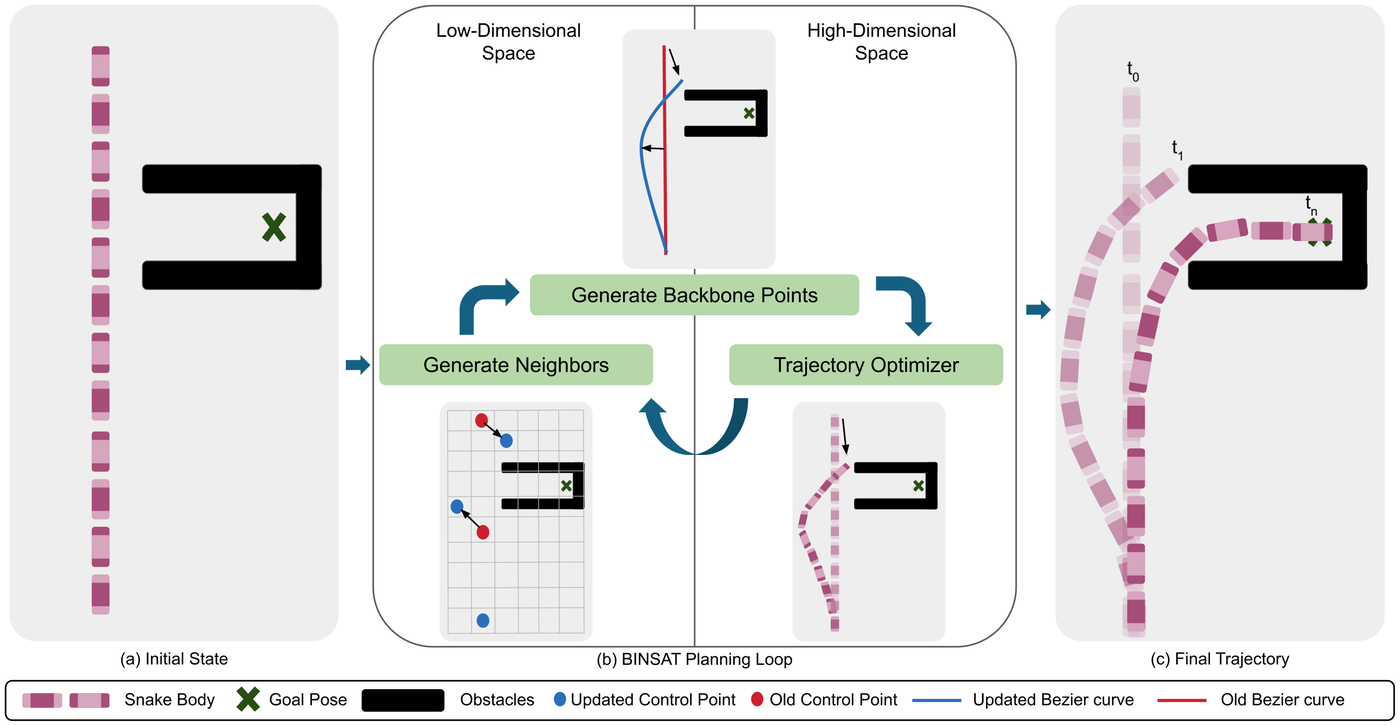
Hierarchical motion planning for high-DoF snake robots

Reaching lets a snake robot anchor its tail and extend across gaps, turning it into a 16-DoF serial manipulator. BINSAT searches over Bézier-curve backbones in 6-D, then lifts each candidate to joint space with a trajectory optimizer that enforces whole-body collision and torque limits.

16→6planning dimensions
98%simulation success
16-DoFhardware deployment
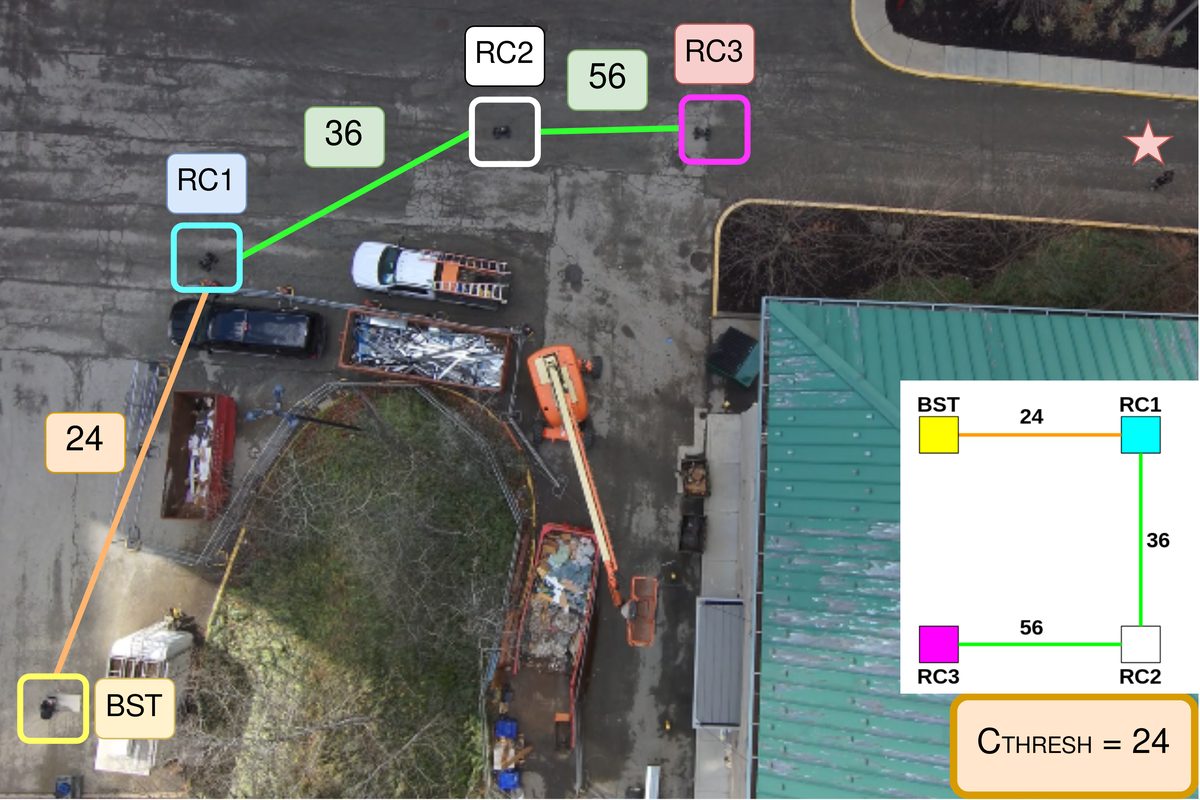
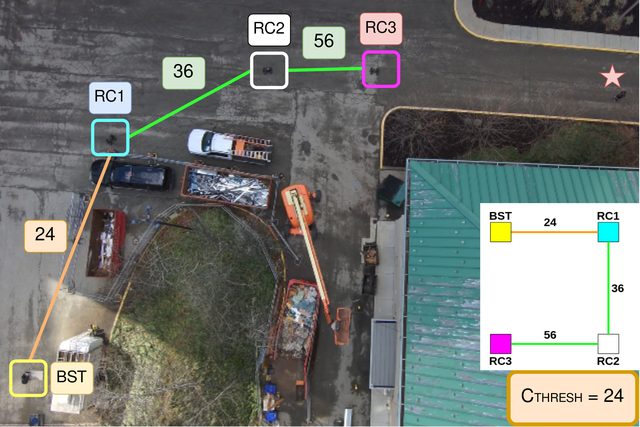
Decentralized convoy, aerial view
GVSETS 2025Field deployment

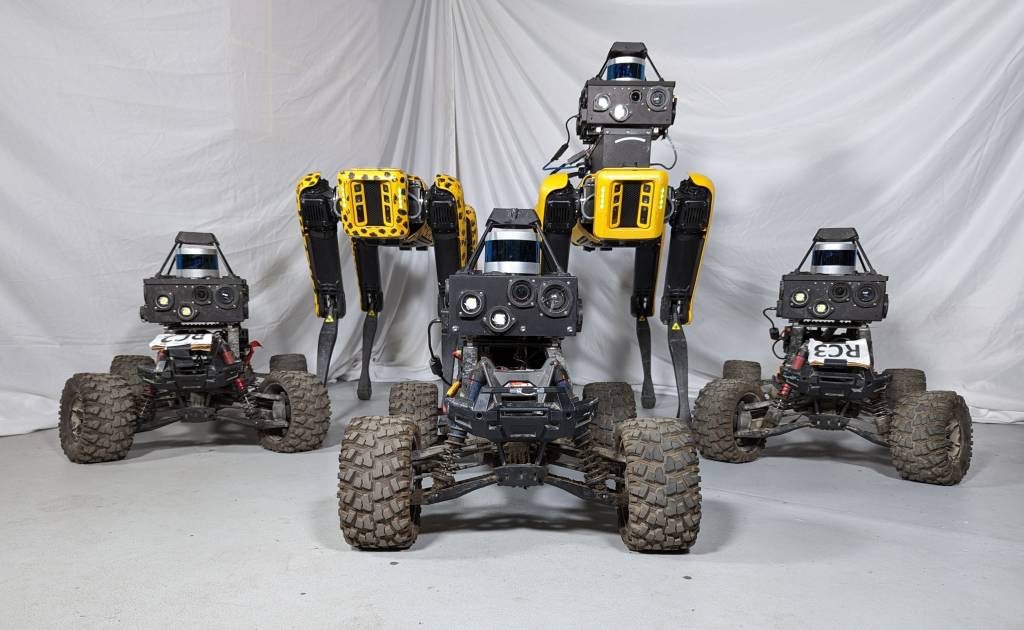
Decentralized heterogeneous convoys and high-speed autonomy

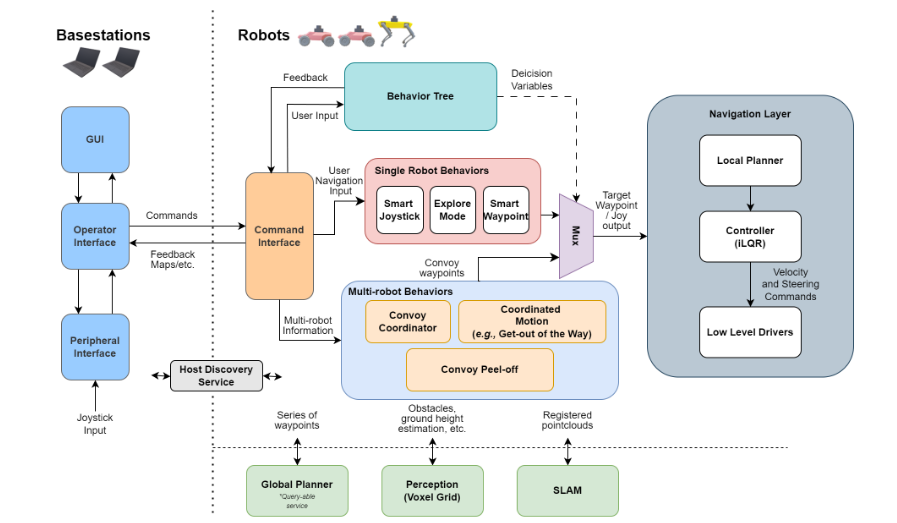
A decentralized planning stack lets mixed teams of wheeled UGVs and Spot quadrupeds form, resize, and hold convoys without a central planner. Compact footprint geometry keeps collision checks fast enough for 20 Hz replanning at 6 m/s, and robots peel off as communication relays to keep the team linked to base.

6 m/sautonomous ground speed
20 Hzonline replanning
UGV+Spotmixed fleet
97.2× Speedup of the lazy ILP allocator, with min-max optimality preserved.
IEEE RA-LAAAI MAPF-W

Scalable multi-agent multi-objective ergodic search

Assigning agents to competing search objectives is combinatorial in team size. I cast allocation as clustering in Fourier space, warm-start it with an infinite-horizon approximation, and solve a lazy ILP that exploits the resulting structure.

97.2×faster allocation
min-maxoptimality kept
ILPlazy constraints
MuJoCo simulation (top) driving the hardware emulator (bottom)
Hardware-in-the-loopSpace robotics

Microgravity docking emulator

Four synchronized UR10e arms reproduce spacecraft proximity operations on the ground. A MuJoCo model computes free-floating and contact dynamics, velocity control on the arms tracks the simulated client and tool-tip states with sub-millimeter, sub-millisecond accuracy, and measured contact forces feed back into the simulation.

4× UR10esynchronized arms
<1 mmtracking accuracy
<1 mssynchronization

02Robotics in action

Silent loops from field and lab experiments
01
Local-minima escapeLocal only vs. global + local planner, simulation
02
Global navigationWheeled UGV, waypoint to waypoint, 4×
03
Quadruped local plannerSpot through doors and clutter
04
3D voxel perceptionVoxel grid to traversability map
05
Heterogeneous convoySpot decoupled, tracking a wheeled convoy
06
Microgravity docking HIL4× UR10e + MuJoCo

03Publications

by year →
  1. Figure from CAP: A Connectivity-Aware Hierarchical Coverage Path Planning Algorithm for Unknown Environments using Coverage Guidance Graph
    IROS 2025
    CAP: A Connectivity-Aware Hierarchical Coverage Path Planning Algorithm for Unknown Environments using Coverage Guidance Graph
    Zongyuan Shen, Burhanuddin Shirose, Prasanna Sriganesh, and Matthew Travers
    2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Oct 2025
    DOIVideo
  2. Figure from Communication Network Construction Behaviors for Robotic Convoying
    GVSETS 2025
    Communication Network Construction Behaviors for Robotic Convoying
    Charles Noren, Sahil Chaudhary, Burhanuddin Shirose, Bhaskar Vundurthy, and Matthew Travers
    Proceedings of the 2025 Ground Vehicle Systems Engineering and Technology Symposium (GVSETS), Aug 2025
    Video
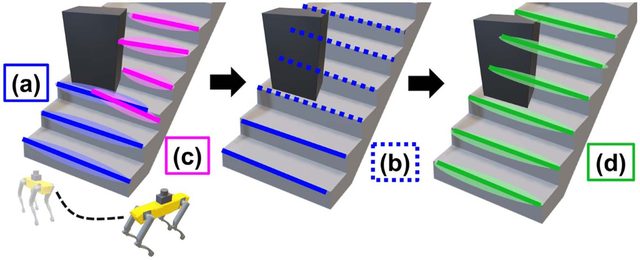
  3. Figure from A Bayesian Modeling Framework for Estimation and Ground Segmentation of Cluttered Staircases
    IEEE RA-L
    A Bayesian Modeling Framework for Estimation and Ground Segmentation of Cluttered Staircases
    Prasanna Sriganesh, Burhanuddin Shirose, and Matthew Travers
    IEEE Robotics and Automation Letters, vol. 10, no. 5, May 2025
    PDFDOI
  4. Figure from GESCE: Graph-based Ergodic Search in Cluttered Environments
    IROS 2024First author
    GESCE: Graph-based Ergodic Search in Cluttered Environments
    Burhanuddin Shirose, Adam Johnson, Bhaskar Vundurthy, Howie Choset, and Matthew Travers
    2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Oct 2024
    DOIProject
  5. Figure from Modular, Resilient, and Scalable System Design Approaches – Lessons Learned in the Years after DARPA Subterranean Challenge
    ICRA-W 2024
    Modular, Resilient, and Scalable System Design Approaches – Lessons Learned in the Years after DARPA Subterranean Challenge
    Prasanna Sriganesh, James Maier, Adam Johnson, Burhanuddin Shirose, Rohan Chandrasekar, Charles Noren, Joshua Spisak, Ryan Darnley, Bhaskar Vundurthy, and Matthew Travers
    IEEE ICRA Workshop on Field Robotics, Apr 2024
    PDF
  6. ISTVS 2024
    ISTVS 2024
    An Interaction-Aware Two-Level Robotic Planning and Control System for Vegetation Override
    Charles Noren, Bhaskar Vundurthy, Sebastian Scherer, Matthew Travers, and Burhanuddin Shirose
    Proceedings of the International Society for Terrain-Vehicle Systems (ISTVS) Conference, 2024
  7. AAAI MAPF-W
    AAAI MAPF-W
    Generalized Multi-Agent Multi-Objective Ergodic Search
    Bhaskar Vundurthy, Geordan Gutow, Akshaya Srinivasan, A. Xu, Burhanuddin Shirose, et al.
    AAAI Workshop on Multi-Agent Path Finding, 2024
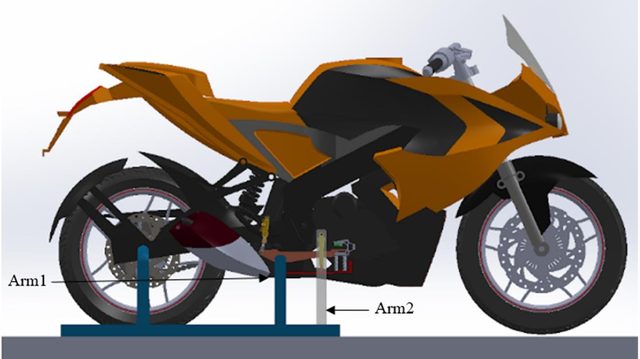
  8. Figure from Robotic Arm for Brake Performance Testing
    RoAI 2021First author
    Robotic Arm for Brake Performance Testing
    Burhanuddin Shirose, Kunal Yadav, L. S. Meenatchi, and K. Vedhanarayan
    Journal of Physics: Conference Series (RoAI 2021), vol. 2251, no. 1, Apr 2022
    DOI
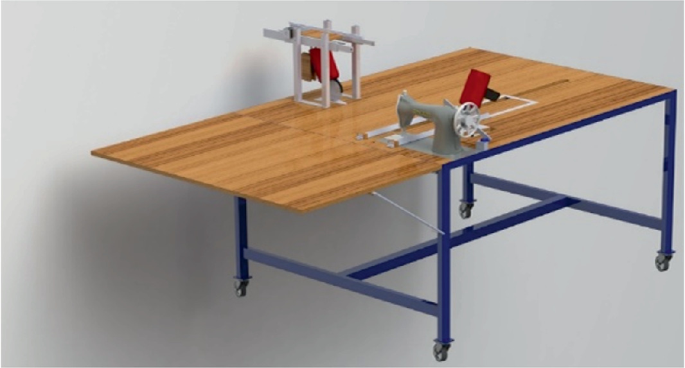
  9. Figure from T-Ceres: An Automated Machine for Any T-Shirt to Bag Conversion
    Springer
    T-Ceres: An Automated Machine for Any T-Shirt to Bag Conversion
    S. Premkumar, Yash Prakash, Burhanuddin Shirose, K. Dhivakar, Mayank Kapur, L. N. Puthiyavan, and Ssmrithi Arul
    Springer, Jan 2022
    DOI
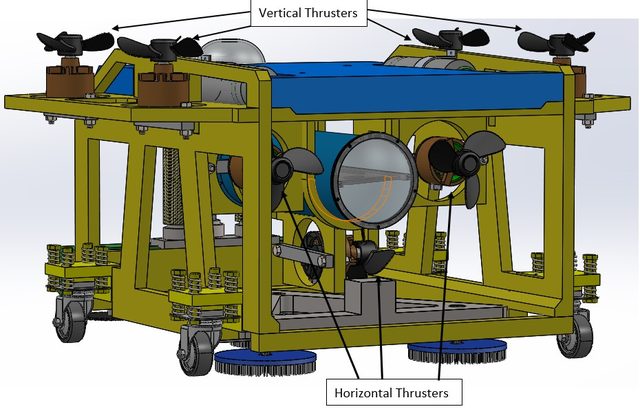
  10. Figure from Design of a Remotely Operated Vehicle (ROV) for Biofoul Cleaning and Inspection of Variety of Underwater Structures
    ICRoM 2021
    Design of a Remotely Operated Vehicle (ROV) for Biofoul Cleaning and Inspection of Variety of Underwater Structures
    Nandha Kizor V, Burhanuddin Shirose, Mainak Adak, Mitesh Kumar, Sudarsana Jayandan J, Arun Srinivasan, and Raashid Sheikh Muhammad
    2021 9th RSI International Conference on Robotics and Mechatronics (ICRoM), 2021
    DOI
Contact

bshirose [at] andrew.cmu.edu

Robotics Institute, Carnegie Mellon University, Pittsburgh, PA

BibTeX