publications
2025
-
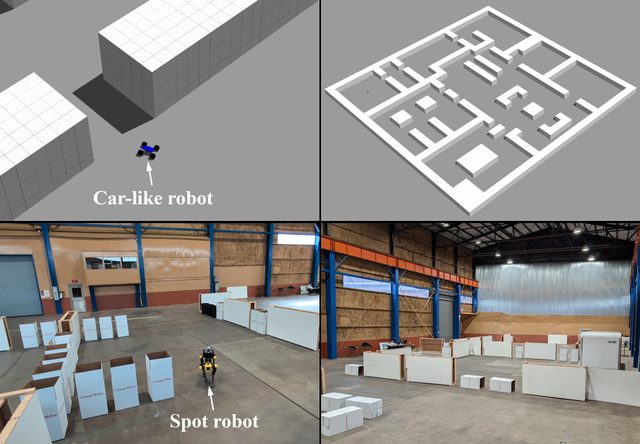 CAP: A Connectivity-Aware Hierarchical Coverage Path Planning Algorithm for Unknown Environments using Coverage Guidance Graph2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Oct 2025
@inproceedings{shen2025cap, title = {{CAP}: A Connectivity-Aware Hierarchical Coverage Path Planning Algorithm for Unknown Environments using Coverage Guidance Graph}, author = {Shen, Zongyuan and Shirose, Burhanuddin and Sriganesh, Prasanna and Travers, Matthew}, booktitle = {2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)}, year = {2025}, month = oct, doi = {10.1109/IROS60139.2025.11247648}, } -
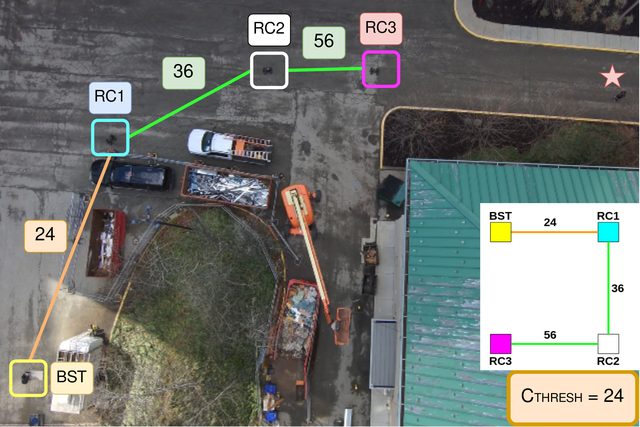 Communication Network Construction Behaviors for Robotic ConvoyingProceedings of the 2025 Ground Vehicle Systems Engineering and Technology Symposium (GVSETS), Aug 2025
@inproceedings{noren2025convoy, title = {Communication Network Construction Behaviors for Robotic Convoying}, author = {Noren, Charles and Chaudhary, Sahil and Shirose, Burhanuddin and Vundurthy, Bhaskar and Travers, Matthew}, booktitle = {Proceedings of the 2025 Ground Vehicle Systems Engineering and Technology Symposium (GVSETS)}, organization = {NDIA}, address = {Novi, MI}, year = {2025}, month = aug, } -
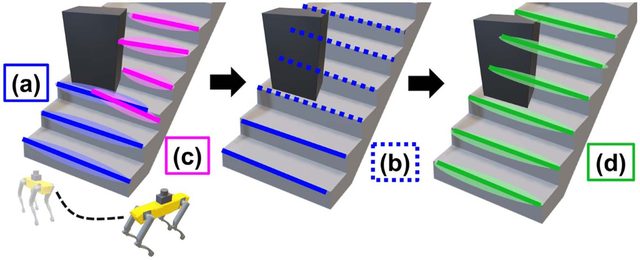 A Bayesian Modeling Framework for Estimation and Ground Segmentation of Cluttered StaircasesIEEE Robotics and Automation Letters, vol. 10, no. 5, May 2025
@article{sriganesh2025stairs,
  title = {A Bayesian Modeling Framework for Estimation and Ground Segmentation of Cluttered Staircases},
  author = {Sriganesh, Prasanna and Shirose, Burhanuddin and Travers, Matthew},
  journal = {IEEE Robotics and Automation Letters},
  volume = {10},
  number = {5},
  pages = {4164},
  year = {2025},
  month = may,
  doi = {10.1109/LRA.2025.3549662},
  eprint = {2501.04170},
  archiveprefix = {arXiv},
  primaryclass = {cs.RO},
}
2024
-
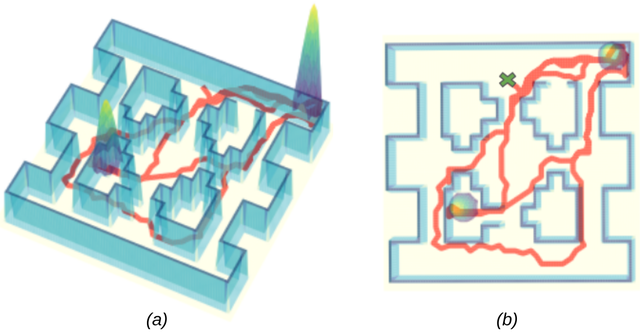 GESCE: Graph-based Ergodic Search in Cluttered Environments2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Oct 2024
@inproceedings{shirose2024gesce, title = {{GESCE}: Graph-based Ergodic Search in Cluttered Environments}, author = {Shirose, Burhanuddin and Johnson, Adam and Vundurthy, Bhaskar and Choset, Howie and Travers, Matthew}, booktitle = {2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)}, pages = {7611--7616}, year = {2024}, month = oct, doi = {10.1109/IROS58592.2024.10802461}, } -
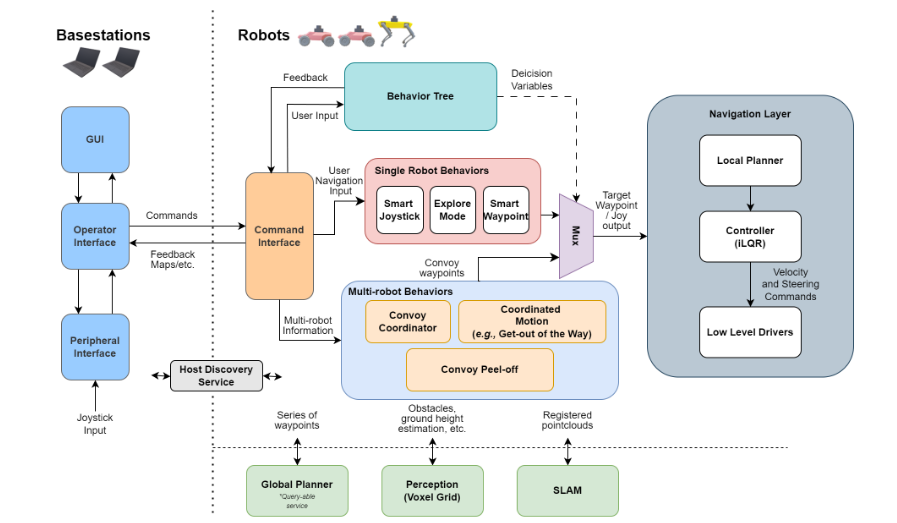 Modular, Resilient, and Scalable System Design Approaches – Lessons Learned in the Years after DARPA Subterranean ChallengeIEEE ICRA Workshop on Field Robotics, Apr 2024
@inproceedings{sriganesh2024subt, title = {Modular, Resilient, and Scalable System Design Approaches -- Lessons Learned in the Years after {DARPA} Subterranean Challenge}, author = {Sriganesh, Prasanna and Maier, James and Johnson, Adam and Shirose, Burhanuddin and Chandrasekar, Rohan and Noren, Charles and Spisak, Joshua and Darnley, Ryan and Vundurthy, Bhaskar and Travers, Matthew}, booktitle = {IEEE ICRA Workshop on Field Robotics}, year = {2024}, month = apr, eprint = {2404.17759}, archiveprefix = {arXiv}, primaryclass = {cs.RO}, } - ISTVS 2024An Interaction-Aware Two-Level Robotic Planning and Control System for Vegetation OverrideProceedings of the International Society for Terrain-Vehicle Systems (ISTVS) Conference, 2024
@inproceedings{noren2024vegetation, title = {An Interaction-Aware Two-Level Robotic Planning and Control System for Vegetation Override}, author = {Noren, Charles and Vundurthy, Bhaskar and Scherer, Sebastian and Travers, Matthew and Shirose, Burhanuddin}, booktitle = {Proceedings of the International Society for Terrain-Vehicle Systems (ISTVS) Conference}, year = {2024}, } - AAAI MAPF-WGeneralized Multi-Agent Multi-Objective Ergodic SearchAAAI Workshop on Multi-Agent Path Finding, 2024
@inproceedings{vundurthy2024moes,
  title = {Generalized Multi-Agent Multi-Objective Ergodic Search},
  author = {Vundurthy, Bhaskar and Gutow, Geordan and Srinivasan, Akshaya and Xu, A. and Shirose, Burhanuddin and others},
  booktitle = {AAAI Workshop on Multi-Agent Path Finding},
  year = {2024},
}
2022
-
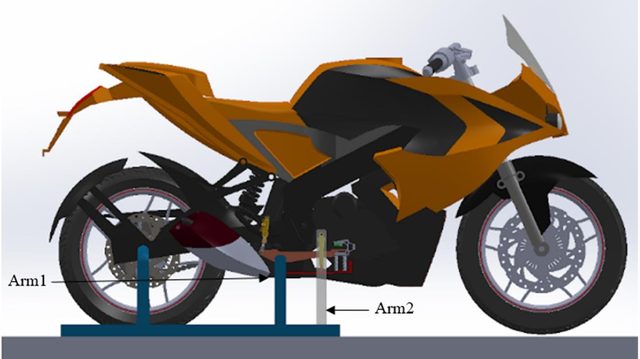 Robotic Arm for Brake Performance TestingJournal of Physics: Conference Series (RoAI 2021), vol. 2251, no. 1, Apr 2022
@article{shirose2022brake, title = {Robotic Arm for Brake Performance Testing}, author = {Shirose, Burhanuddin and Yadav, Kunal and Meenatchi, L. S. and Vedhanarayan, K.}, journal = {Journal of Physics: Conference Series (RoAI 2021)}, publisher = {IOP Publishing}, volume = {2251}, number = {1}, pages = {012002}, year = {2022}, month = apr, doi = {10.1088/1742-6596/2251/1/012002}, } -
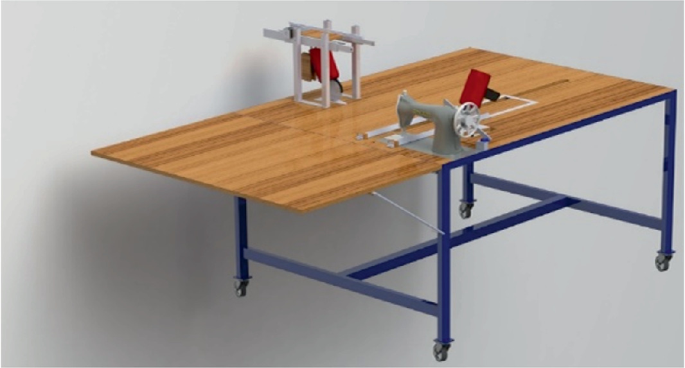 T-Ceres: An Automated Machine for Any T-Shirt to Bag ConversionSpringer, Jan 2022
@inbook{premkumar2022tceres,
  title = {T-Ceres: An Automated Machine for Any T-Shirt to Bag Conversion},
  author = {Premkumar, S. and Prakash, Yash and Shirose, Burhanuddin and Dhivakar, K. and Kapur, Mayank and Puthiyavan, L. N. and Arul, Ssmrithi},
  publisher = {Springer},
  pages = {247--257},
  year = {2022},
  month = jan,
  isbn = {978-981-19-0295-6},
  doi = {10.1007/978-981-19-0296-3_22},
}
2021
-
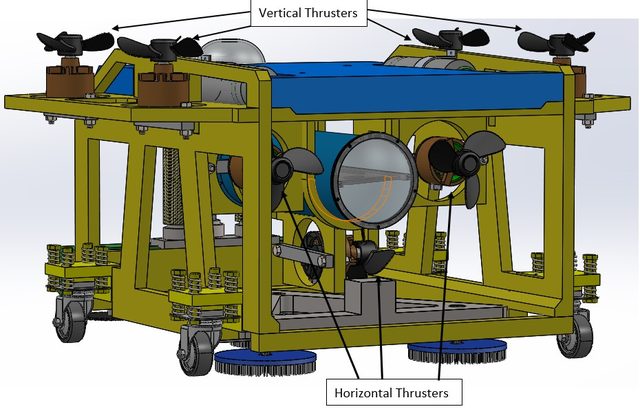 Design of a Remotely Operated Vehicle (ROV) for Biofoul Cleaning and Inspection of Variety of Underwater Structures2021 9th RSI International Conference on Robotics and Mechatronics (ICRoM), 2021
@inproceedings{kizor2021rov,
  title = {Design of a Remotely Operated Vehicle ({ROV}) for Biofoul Cleaning and Inspection of Variety of Underwater Structures},
  author = {V, Nandha Kizor and Shirose, Burhanuddin and Adak, Mainak and Kumar, Mitesh and J, Sudarsana Jayandan and Srinivasan, Arun and Muhammad, Raashid Sheikh},
  booktitle = {2021 9th RSI International Conference on Robotics and Mechatronics (ICRoM)},
  pages = {451--457},
  publisher = {IEEE},
  year = {2021},
  doi = {10.1109/ICRoM54204.2021.9663518},
}